Preprint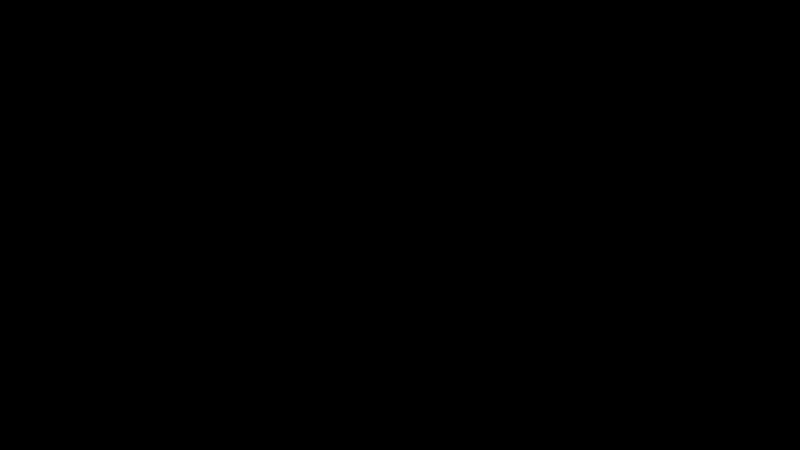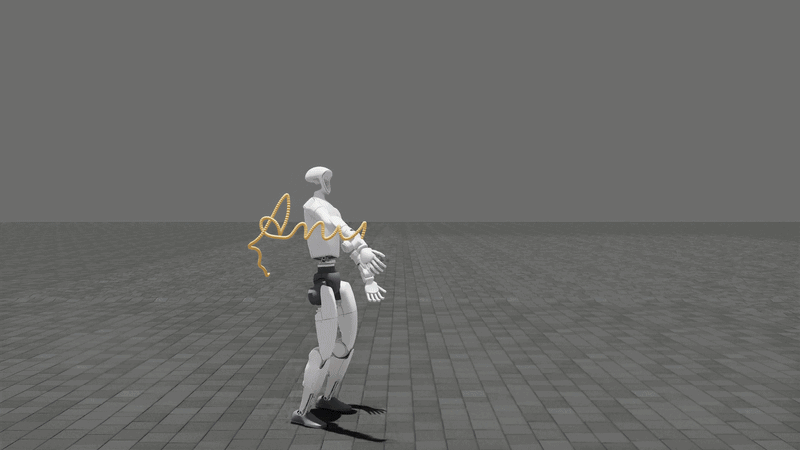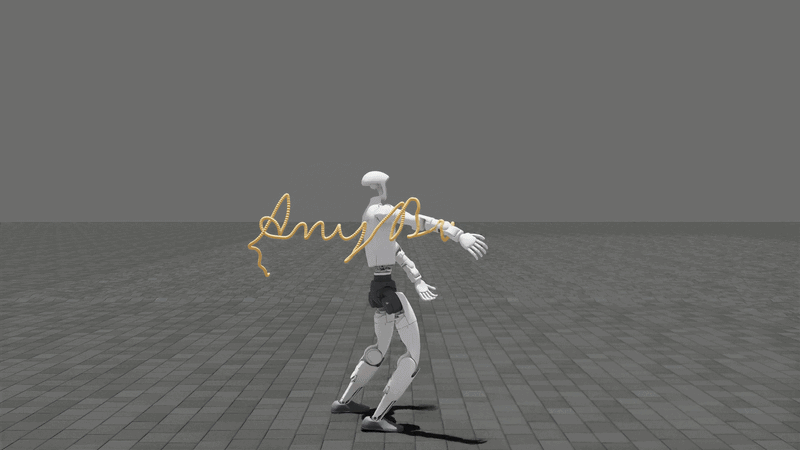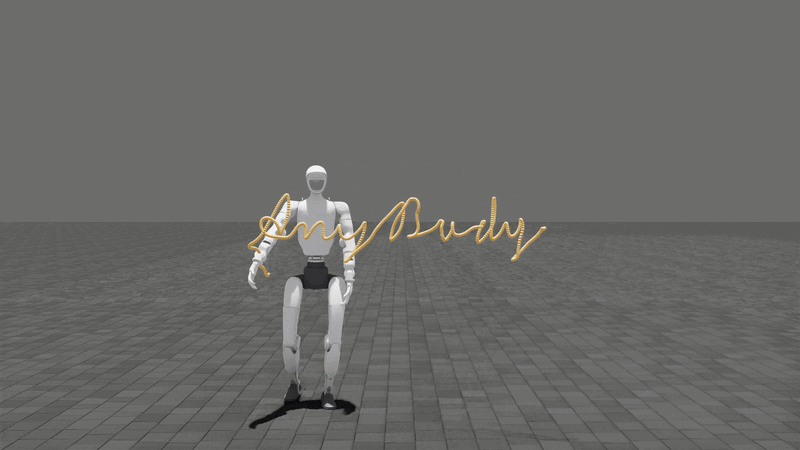
AnyBody: Free-Form Whole-Body Humanoid Control from Arbitrary Keypoint Guidance
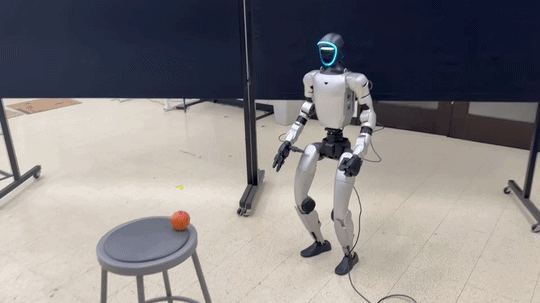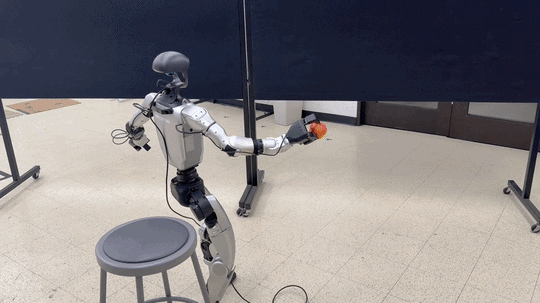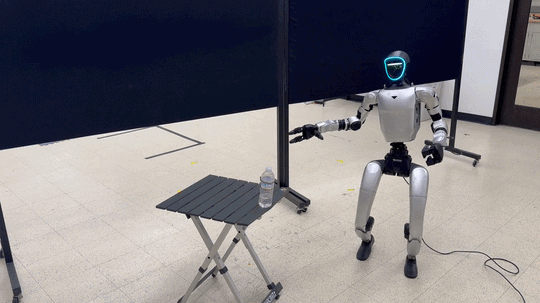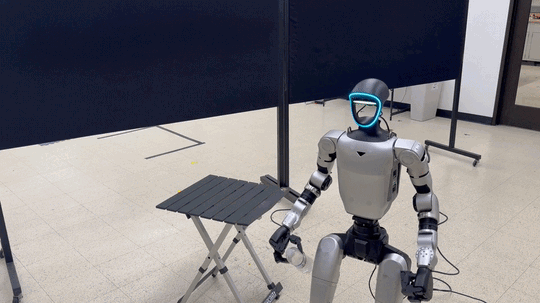
- We present AnyBody, a unified whole-body humanoid controller driven by an arbitrary subset of body keypoints chosen at deploy time.
Hi! I’m Shuning Li 李姝凝, and I also go by Suzanna or Sue. I’m a senior undergraduate in the Tsien Excellence in Engineering Program at Tsinghua University, majoring in Theoretical and Applied Mechanics.
I’m currently a visiting student at UC Berkeley, working with Prof. Masayoshi Tomizuka and Prof. Mingyu Ding. I’ve also had the opportunity to work under the guidance of Prof. Jiachen Li. Along the way, I was fortunate to work closely with Yuman Gao and Sikai Li.
My research focuses on embodied intelligence: how agents learn to reason and act in the physical world. I am particularly interested in connecting high-level reasoning with reusable physical skills, enabling robots to adapt to new tasks and environments.
I am applying to PhD programs for Fall 2027. Please feel free to get in touch!